
STL Research’s Janus motion platform is available for hire
Our Janus 63 motion platform, is capable of moving in six degrees of freedom (pitch, roll, yaw, heave, surge, and sway). The motion platform has many possible applications, as it …

Motion-compensated personnel-access system (PAS) and light crane.
The Neptune 20M system enables transfer of personnel with equipment or cargo from a vessel via a gondola, to a fixed or floating offshore structure with full (6DoF) motion-compensation to remove wave induced motions, with the payload arriving at the target structure with no relative movement between them.

Ship-Based Robotic Arm for Autonomous Launch And Recovery (LAR) Operations.
The Proteus Launch and Recovery Systems with integrated machine vision, are innovative, stand-alone, deck mounted solutions, that enable the safe launch and recovery of autonomous or semi-autonomous marine equipment; such as ROVs, AUVs and ASVs, under local or remote control.
Should you require any additional information, please contact us here

Six degree of freedom (6DOF) Motion Platform.
A variant of the classic ‘Stewart Table’ or ‘Hexapod’, similar to those found in flight simulators. STL’s Janus platforms are offered for purchase and can be tailored to customer requirements.
STL’s own 63 Series Janus platform is also commercially available to hire for third party work, at our Isle of Wight facility.
STL Research is a consultancy, design, development and project implementation group, specialising in motion compensation, control and automation for the offshore and sub-sea industries.
Initially operating from Aberdeen and now based in Cowes, STL Research has been involved in many leading edge projects within the offshore and subsea markets. Two key focus areas are safe and efficient personnel access (Neptune), and the safe launch and recovery of autonomous marine equipment under local or remote control (Proteus).
The Neptune 20M Personnel Access System enables transfer of personnel with equipment, or cargo, from a vessel via a gondola, to a fixed or floating, offshore structure with full (6DoF) motion-compensation to remove wave-induced motion.
Proteus is an innovative, stand-alone, deck mounted launch and recovery system, which uses computer vision to automatically synchronise movement of the interchangeable coupling tool with the target, to eliminate wave-induced motions, simplifying attachment and safe retrieval of ROVs, AUVs and ASVs.
Legacy projects include diving systems, hyperbaric lifeboats, HP/HT valves, well head control & monitoring systems and automatic ultrasonic NDT.
You can find a PDF copy of the Neptune datasheet on our Downloads page.

Neptune 20M Personnel Access System
The Neptune system enables transfer of personnel with equipment or cargo, from a vessel via a gondola, to a fixed, or floating, offshore structure with full (6DoF) motion-compensation to remove wave-induced motions.
If the target is fixed and stationary, vessel induced motion is removed from the gondola, and it is said to be “space stabilised”. If the target is floating and also subject to wave action, the gondola and target motions are matched, and it is said to be “synchronised”.
A stand-alone system that can be installed on any suitable vessel and operates without requiring any vessel services or data, except for the optional use of ship-generated electrical power.
The system has five ‘joints’ and these are highlighted in Figure 1. The foundation, is fixed to the vessel deck and therefore moves with the vessel.

| Slew: | Rotates the entire Neptune system around the vertical axis. |
| Gimbal: | Keeps the arms in a vertical plane as the vessel rolls and pitches. |
| Shoulder: | Rotates the upper arm relative to the gimbal top frame. |
| Elbow: | Rotates the forearm relative to the upper arm. |
| Wrist: | Rotates the gondola relative to the forearm to keep the floor horizontal. |
When in space-stabilised mode, the vessel deck movement is measured in real time using an integral Position and Attitude Sensing System (PASS). This obtains position from Global Navigation Satellite System (GNSS) satellites using Real Time Kinematic (RTK) techniques to enhance precision. This position, along with data from an Inertial Navigation System (INS), is used to generate a PASS output that the Neptune controllers use to calculate joint angles to space-stabilise the gondola.
In synchronised mode (i.e. gondola motion matched with a moving target) a Remote Sensing System (RSS) measures the motion of the floating target. The Neptune controllers use RSS data to derive the joint angles needed to synchronise gondola and moving target motions.
Simulations (Figure 2), and sea trials (Figure 3) have proven Neptune capable of operating at Significant Wave Heights (Hs) up to 2m even on smaller vessels, for example on a 54m mono hull and a 36m catamaran.
| Height capability above deck: | 20.4m when on a standard mounting frame |
| Typical transfer height: | 17m above sea level |
| The operating height can be increased by mounting the unit on a pedestal. | |
| Reach from centre of slew axis: | greater than 21m |
| Vessel stand-off: | greater than 10m (typically 14 to 17m) |
| Slewing capability: | 295° (typically limited to 233º depending on installation) |
| Motion compensation accuracy: | Better than ± 10 cm |
| Maximum system individual motion compensation ability: | |
| Heave: | 5 m |
| Roll: | ± 10° |
| Pitch: | ± 10° |
| Yaw: | ± 147.5° |
| Sway: | ± 2 m Sway and Surge: in addition to |
| Surge: | ± 2 m a 3m diameter watch keeping circle |
| Weight | 11.3 t (excluding hydraulic power unit) |
| Foundation footprint | 2.5 m x 3 m |
| Hydraulic power unit | 2 x 120 kW (diesel or electric) |
| Gondola capacity | 3 people including PPE and tools |
| Payload in personnel mode | 300kg maximum |
| Payload in crane mode | 700kg maximum |
1. Motion compensation figures can be achieved with wave periods as short as 5 seconds.
2. Computer modelling, with ship-motion predictions, can be carried out to determine performance limits for a specific vessel if required.

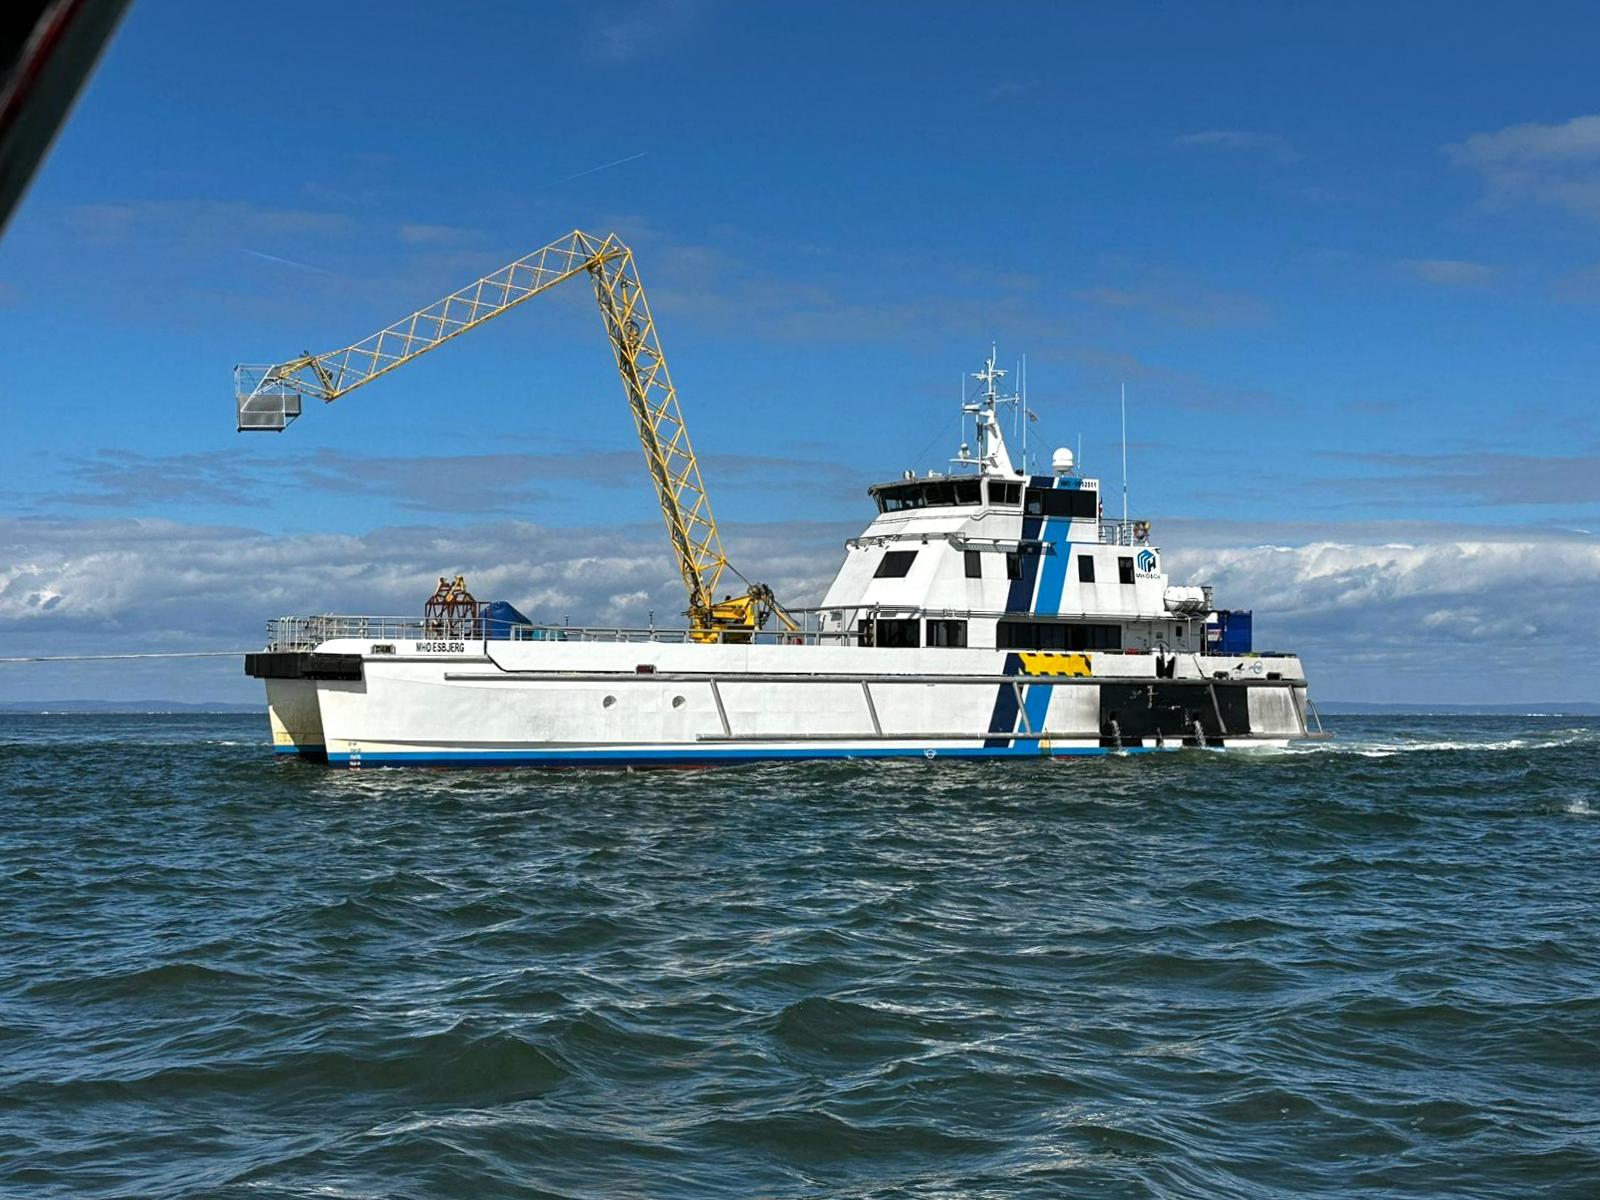
Figure 4 shows a typical installation on a Fast Crew Transfer Vessel with an aluminium hull. The components shown in blue are the deck mounting frame and stowage cradle.

Design for safety is a key principle and is achieved in the following ways:
Designed to the requirements of DNV-ST-0358 Standard for Offshore Gangways and
DNV-ST-0378 Standard for Offshore and Platform Lifting Appliances.
Certification available to this or other equivalent classification society standards.
Conforms to HSE recommended ± 10 cm movement envelope.

You can find a copy of the Proteus 200 datasheet on our Downloads page.
Proteus – Launch and Recovery System (LARS)
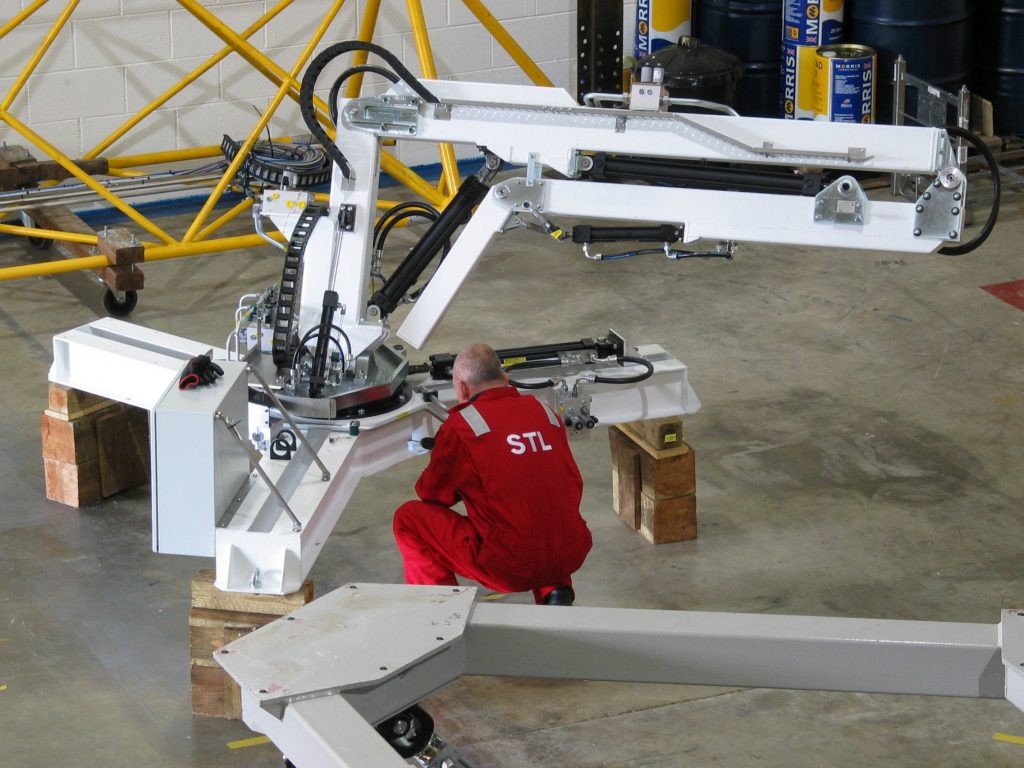
With financial support from the Marine Challenge Fund (part of the ERDF’s European and Structural Funds Growth programme 2014-2020), STL Research have developed a multi-axis robotic arm for ship-based deployment.
The arm, known as Proteus, is designed to simplify the launch and recovery operations of AUVs, ROVs and ASVs, by automatically tracking their position and stabilising its connection tool to compensate for any wave induced vessel and target motion. Proteus makes this process faster and safer for all involved and can even be installed and used on autonomous surface vessels (ASVs) to enable them to execute intervention tasks – e.g. equipment transfers, survey and inspection, or launch and recovery operations.
Our Proteus Launch and Recovery Systems now have their own dedicated site, which can be visited by clicking here, or on the image below.
You can find a PDF copy of the Janus motion platform datasheet on our Downloads page.


A turnkey hydraulic motion platform that can be installed indoors or outdoors (depending on the variant and application) and operated via a standard laptop or desktop PC.
The Janus motion platform has many possible applications, as it can simulate the types of motion and forces found in real-world operating environments. One example is the motion experienced by equipment mounted on the deck of a vessel. Equipment intended for marine use may be mounted on the top frame of the platform to test its performance when subjected to the pitch, roll, yaw, heave, surge and sway motions expected during operation.
The top and bottom frames of the motion platform are connected by six hydraulic cylinders, each with an associated position sensor. The sensors monitor the extension of the cylinder rods and feed back the data to the position controller, ensuring that the movement demanded by the control system is accurately achieved.
The Janus Motion Platform is currently available in two variants, designed for different payload weights and size requirements; the larger 63 Series and the smaller 25 Series, however the design is readily scalable for other applications.

The main system controller is an embedded computer running proprietary STL Research software, mounted in a cabinet along with I/O interface modules and a 24VDC power supply. The cabinet is free-standing to allow flexible positioning and is connected to the motion platform via an umbilical in protective ducting.
The user interface is accessed using a standard PC or laptop, and allows the motion platform to be controlled in the following modes:
Pressurised oil is supplied to the hydraulic cylinders from a separate hydraulic power unit (HPU), via dedicated Digital Servo-proportional Valves with integrated position controllers. In this way, the extension of the cylinders may be precisely and independently controlled.
| 25 Series | 63 Series | |
|---|---|---|
| Pitch | ± 27.0° | ± 31.0° |
| Roll | ± 20.0° | ± 25.4° |
| Yaw | ± 31.0° | ± 41.6° |
| Heave | ± 0.14m | ± 0.42m |
| Surge | ± 0.27m | ± 0.88m |
| Sway | ± 0.24m | ± 0.76m |
| Maximum Payload | 1.0 Tonne * | 8.0 Tonnes* |
| System Weight | 110kg (approx) | 1.5 Tonnes |
Normal permitted range for dynamic operation (for static positioning, the maximum displacements are slightly greater as the cylinders can be safely extended/retracted to their limits)
*Max payload is dependent on acceleration and range of movement required. If you have a requirement for a particular combination of motions, please contact us for more information

Design for safety is a key principle and is achieved in the following ways:
STL’s six degree of freedom (6DOF), Janus 63 Series Motion Platform is commercially available for hire at our Isle of Wight facility. Please contact us here if you would like to know more.
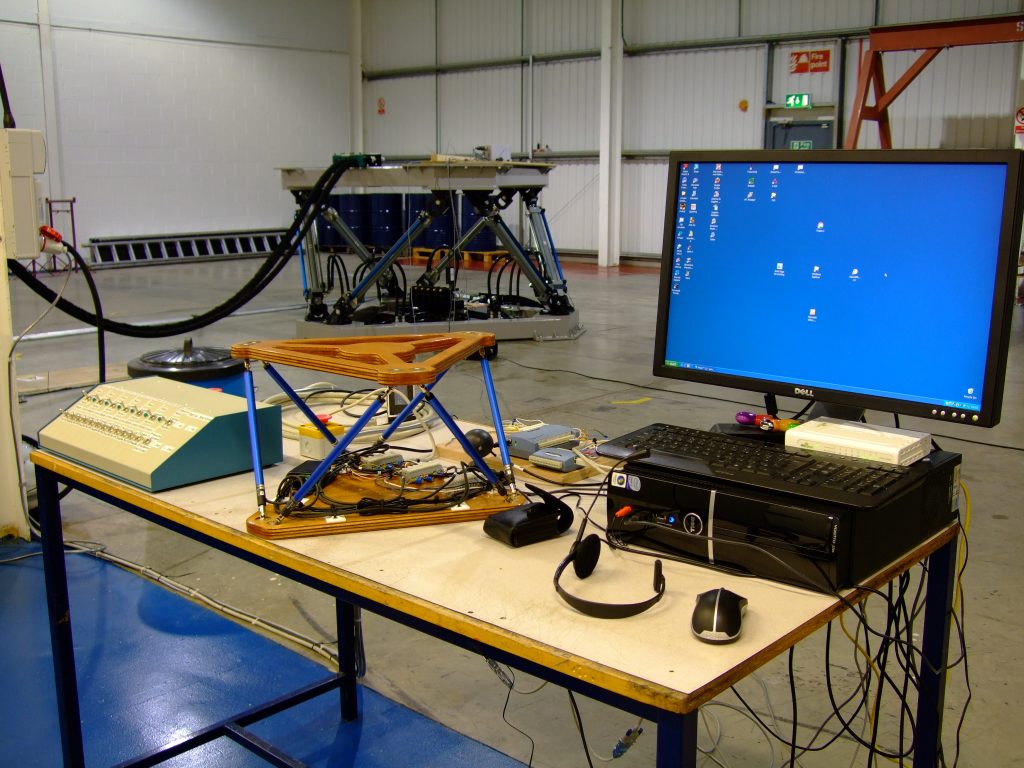
STL’s own Motion Platform may be controlled using the following methods:

STL Research are committed to taking innovative technological concepts, developing them into a practical and economically viable state, and creating commercially successful ventures using the technologies.
Specialising in Motion Compensation, Control & Automation for maritime and offshore industries, STL is ideally placed to take innovative & cutting-edge sub-sea and offshore technology IP from its infancy, to eventual IPO or trade sale.
If you would like further information or are interested in our services, please contact us here.


Our Janus 63 motion platform, is capable of moving in six degrees of freedom (pitch, roll, yaw, heave, surge, and sway). The motion platform has many possible applications, as it …
Over the past few months, STL Research have been very active in exhibiting at, and attending several exhibitions, and we would like to thank everyone who took the time to …
STL Research have produced a video simulation of their Proteus Launch and Recovery system deployed on a fully autonomous uncrewed surface vessel. The video illustrates Proteus’ capabilities with respect to …